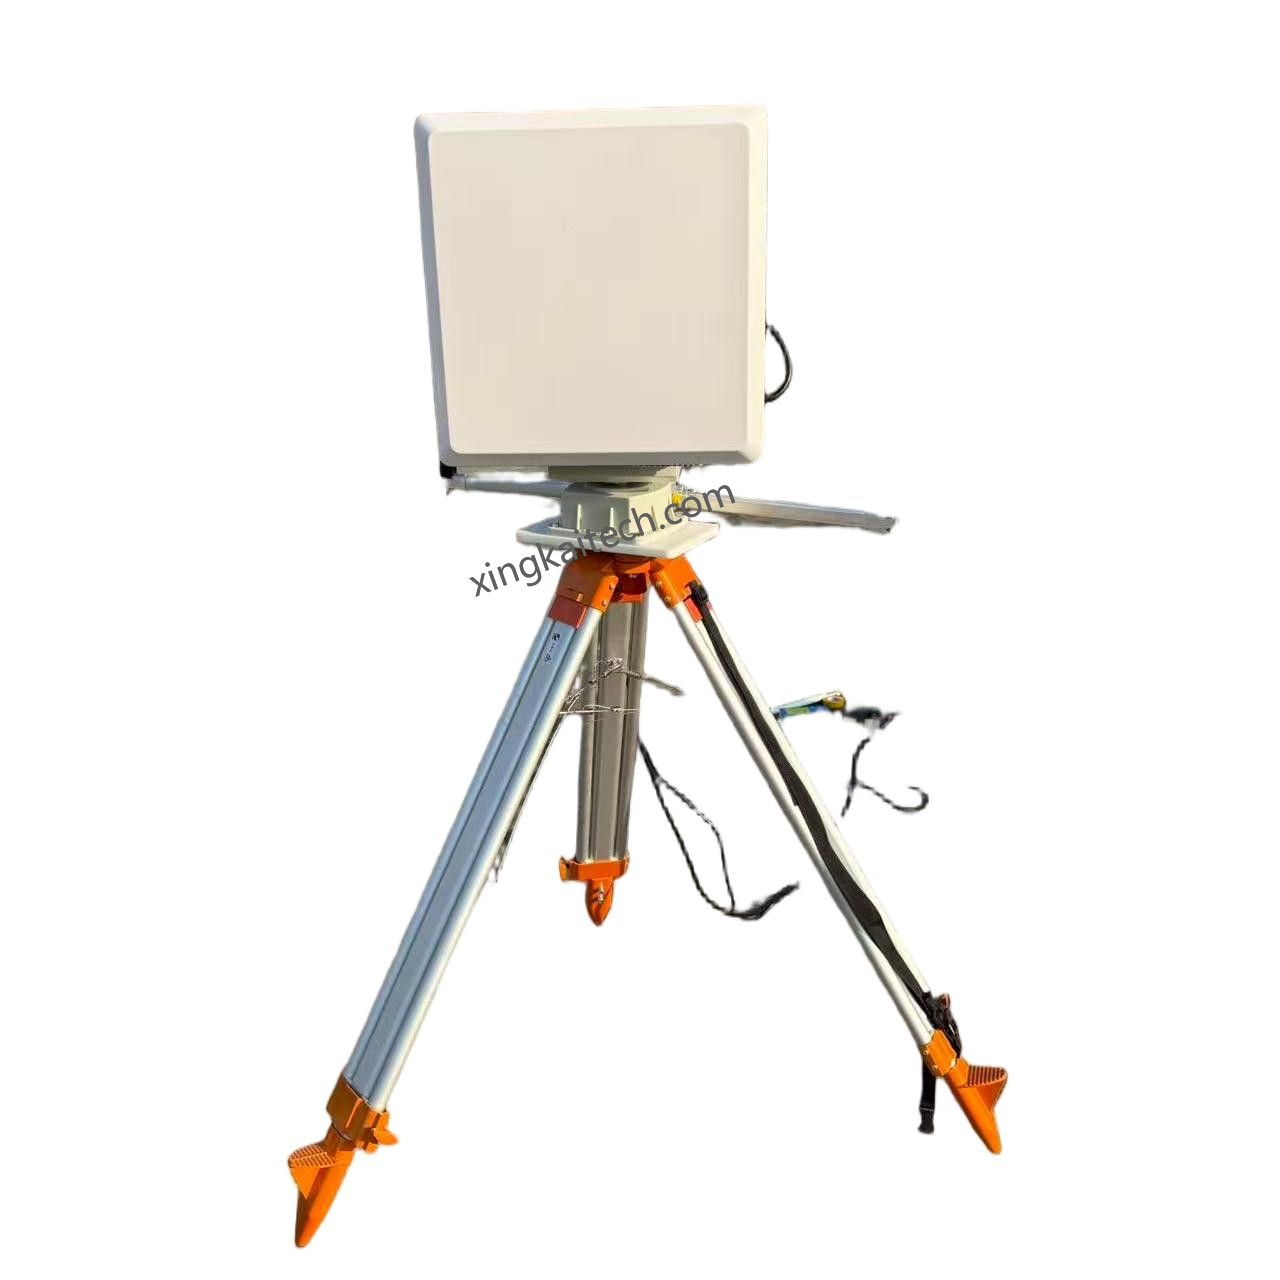
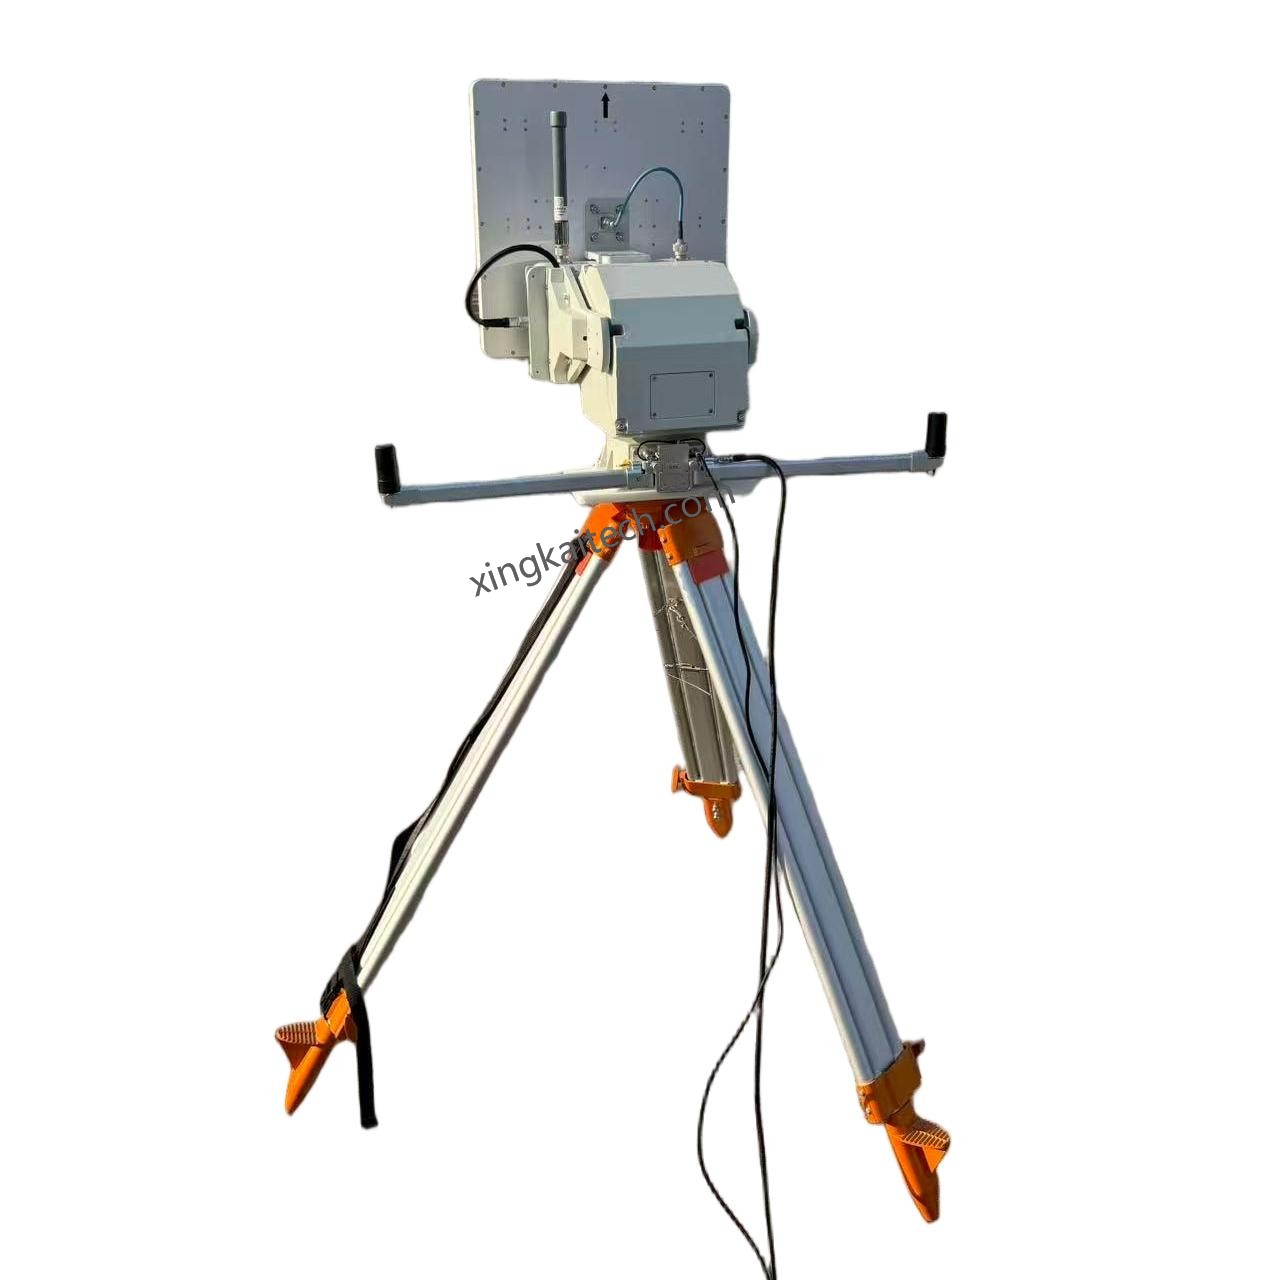
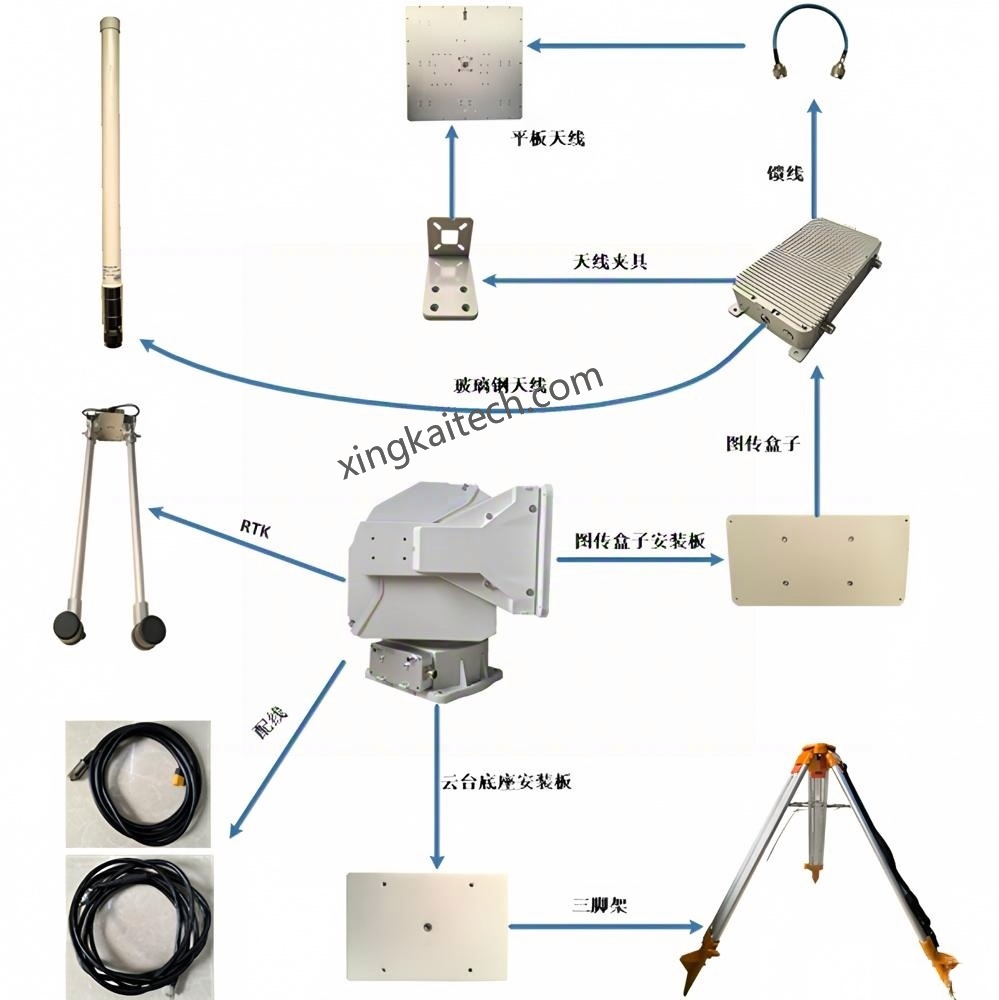
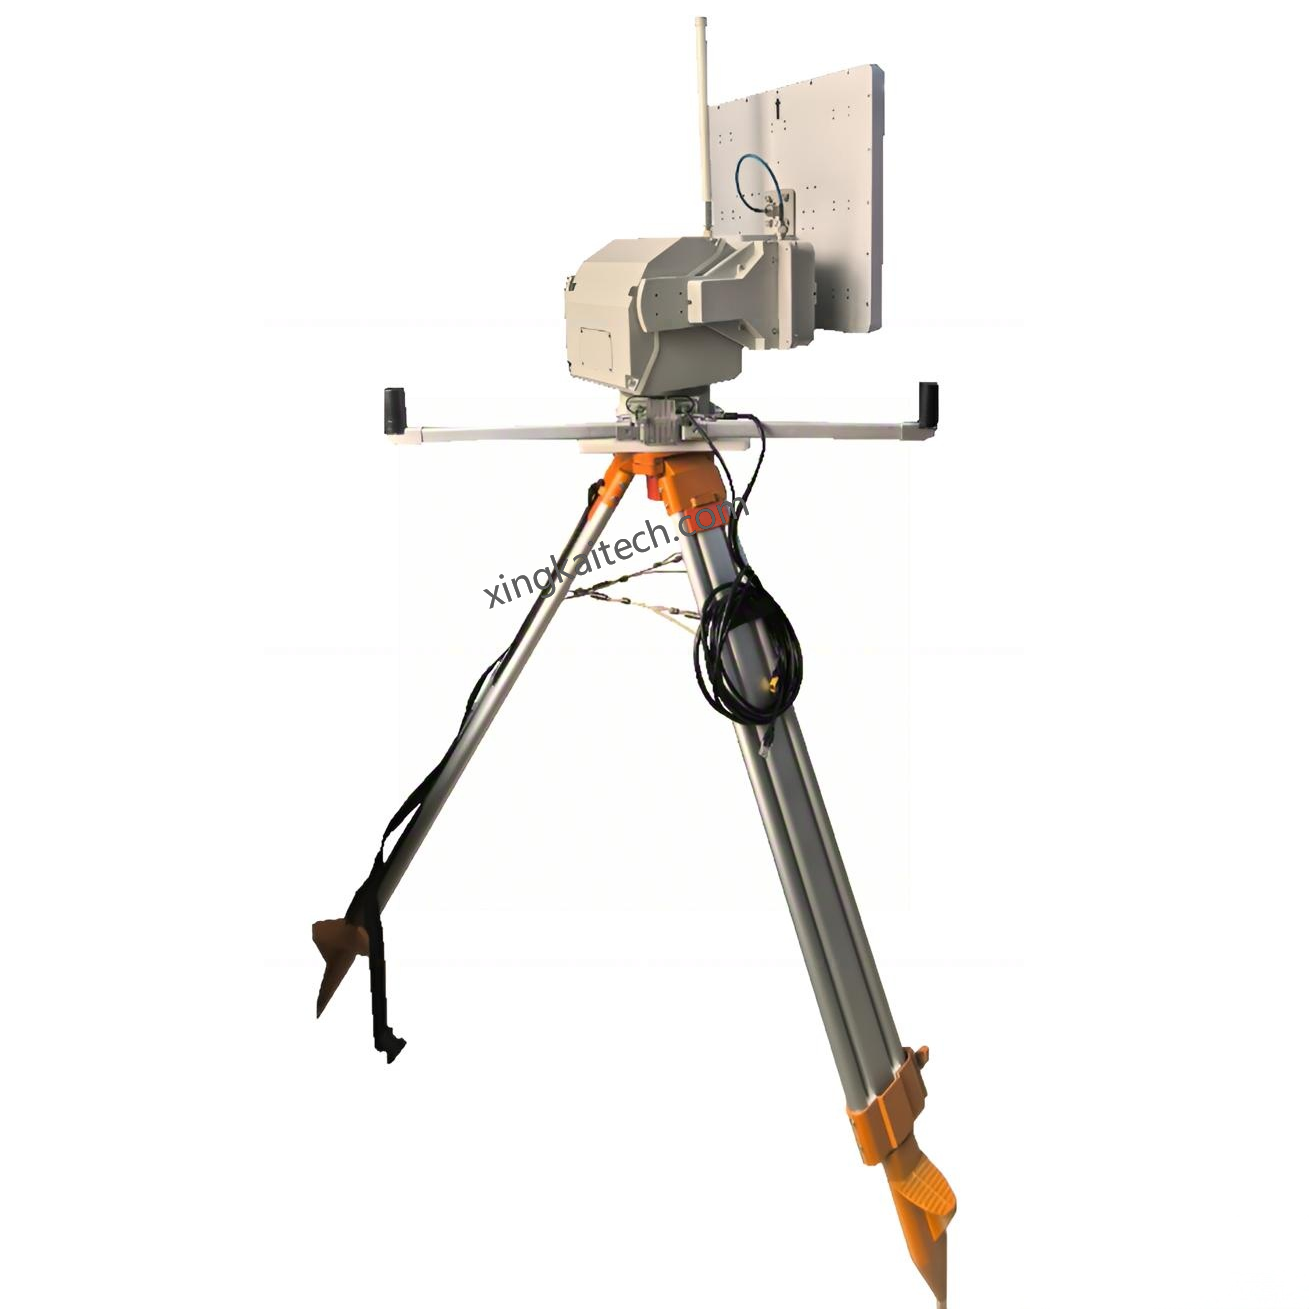
Heavy-Duty Cross Tracking Gimbal
1. Before powering on the device, an antenna or attenuator, or other load, must be properly installed on the RF output interface,otherwise, the internal power amplifier module of the device may be damaged.
2. When replacing the antenna, the power supply must be disconnected first,otherwise, the internal power amplifier module of the device may be damaged.
3. The antenna should be matched to the equipment as closely as possible (including impedance, frequency, and power),otherwise, it may cause damage to the internal power amplifier module of the equipment.
4. Please supply power to the device using a DC 24V power supply,otherwise, it may cause circuit damage or abnormal device operation.
5. Ensure that the antenna of the front-end equipment is installed as exposed as possible in the air, avoiding obstruction by any obstacles,otherwise, the communication range may be compromised.
6. During installation, use a level to verify that the device is placed in a horizontally balanced position.
I. Parameters
| Input Voltage | DC24V |
| Power Consumption | ≤90 W (Gimbal) + ≤**W (Video Link) |
| Output Power | ≤48 W (Powered through the tracker’s rotating mechanism) |
| Horizontal Rotation Range | 0~360°(Unlimited) |
| Pitch Range | 0~90 ° |
| Maximum Horizontal Speed | 60 °/s |
| Maximum Pitch Speed | 30 °/s |
| Horizontal Accuracy | 0.1 ° |
| Pitch Accuracy | 0.1 ° |
| Protection Rating | IP66 |
| Operating Temperature | -35℃~66℃ |
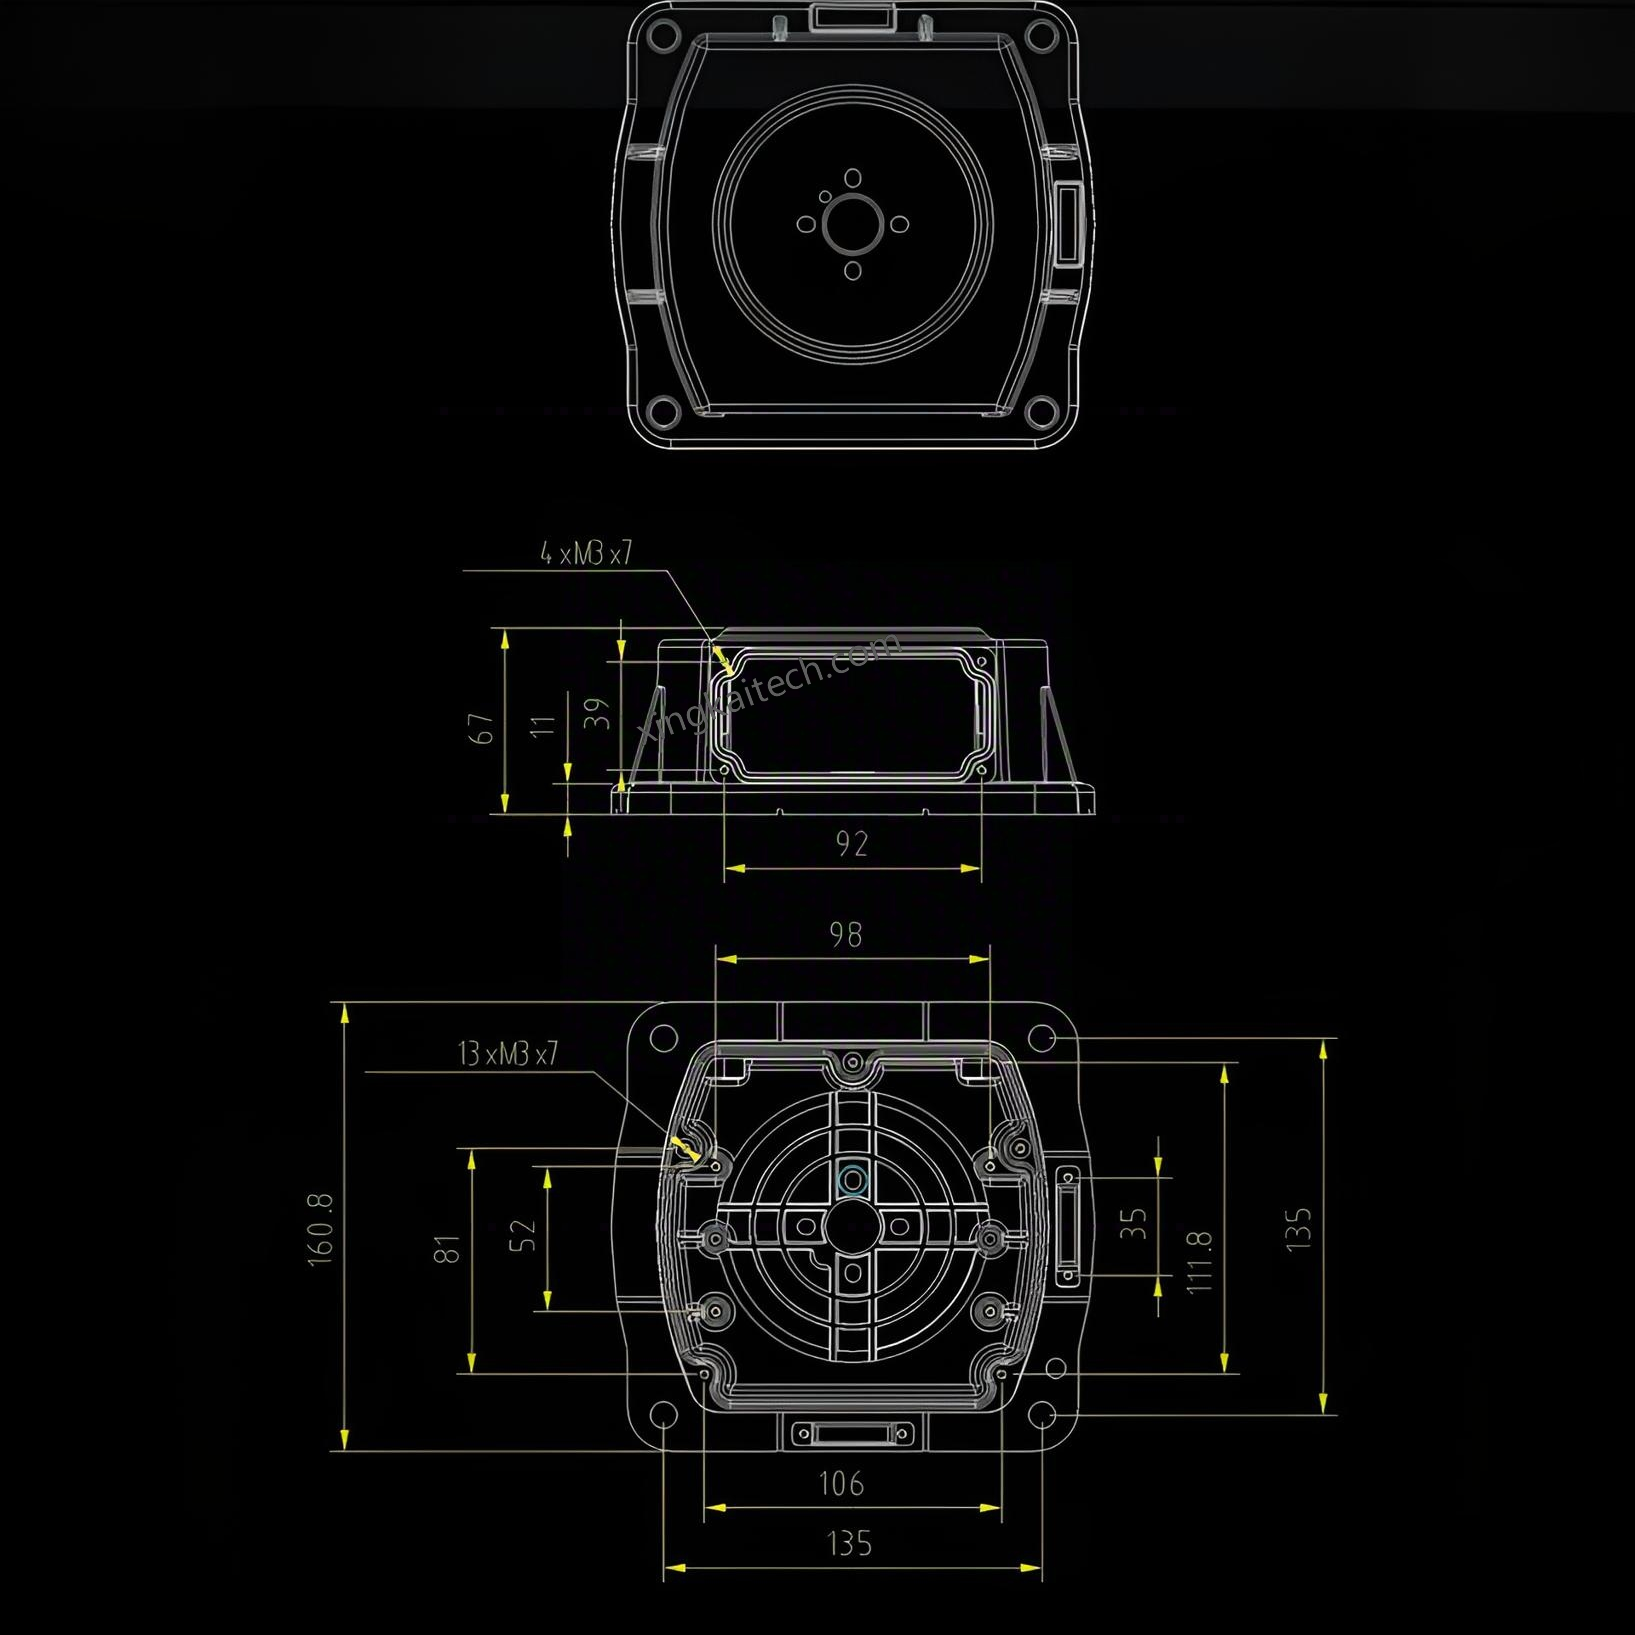
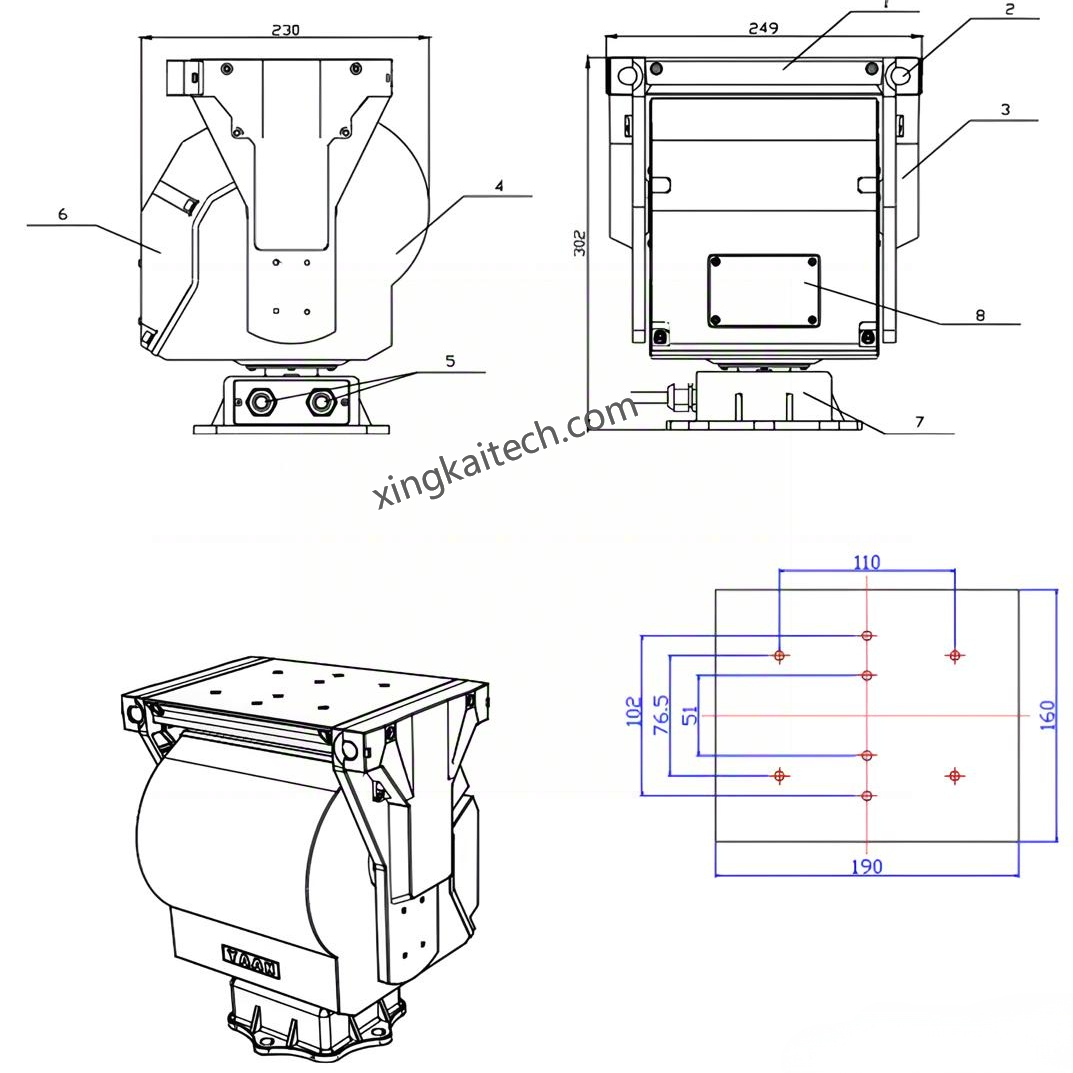
| Dimensions | 249*230*305mm |
| Weight | 13kg |
| Maximum Payload | 15.5kg |
| Supported Protocols | MAVLink 1.0, MAVLink 2.0, NMEA 0183 MFD Protocol, and 8 different autopilot protocols |
| Local Differential GPS | Standard configuration |
| Tracking While Moving | Yes |
| Video Link Box | Optional: 50–200 km |
Related Products